WARA-PS Demonstration Week 2026: Assuring the Safety of Maritime ASVs with SceneGEMS
- Period
- 14 Sep 2026
- Organisation
 WASP Research Arena for Public Safety (WARA-PS)
- Location
- Gränsö Slott, WARA-PS test siteGränsövägen, 593 92 Västervik, Sweden
- Posted
Presentation of SceneGEMS as an end-to-end framework, from scenario generation to simulation execution, at the WARA-PS demonstration week, in front of researchers, industry partners, government agencies and end users.
- SceneGEMS integrated with the WARA-PS core system
- Simulated vessels driven over WARA-PS MQTT topics
WARA-PS, the WASP Research Arena for Public Safety, gives researchers a shared infrastructure of real and simulated vehicles, the core system, and an archipelago test site at Gränsö near Västervik. Its demonstration week is a major annual event in Sweden that brings together researchers, industry partners, government agencies and end users to evaluate AI, autonomous systems and robotics in realistic public-safety scenarios. Projects use it to show what works on that infrastructure.
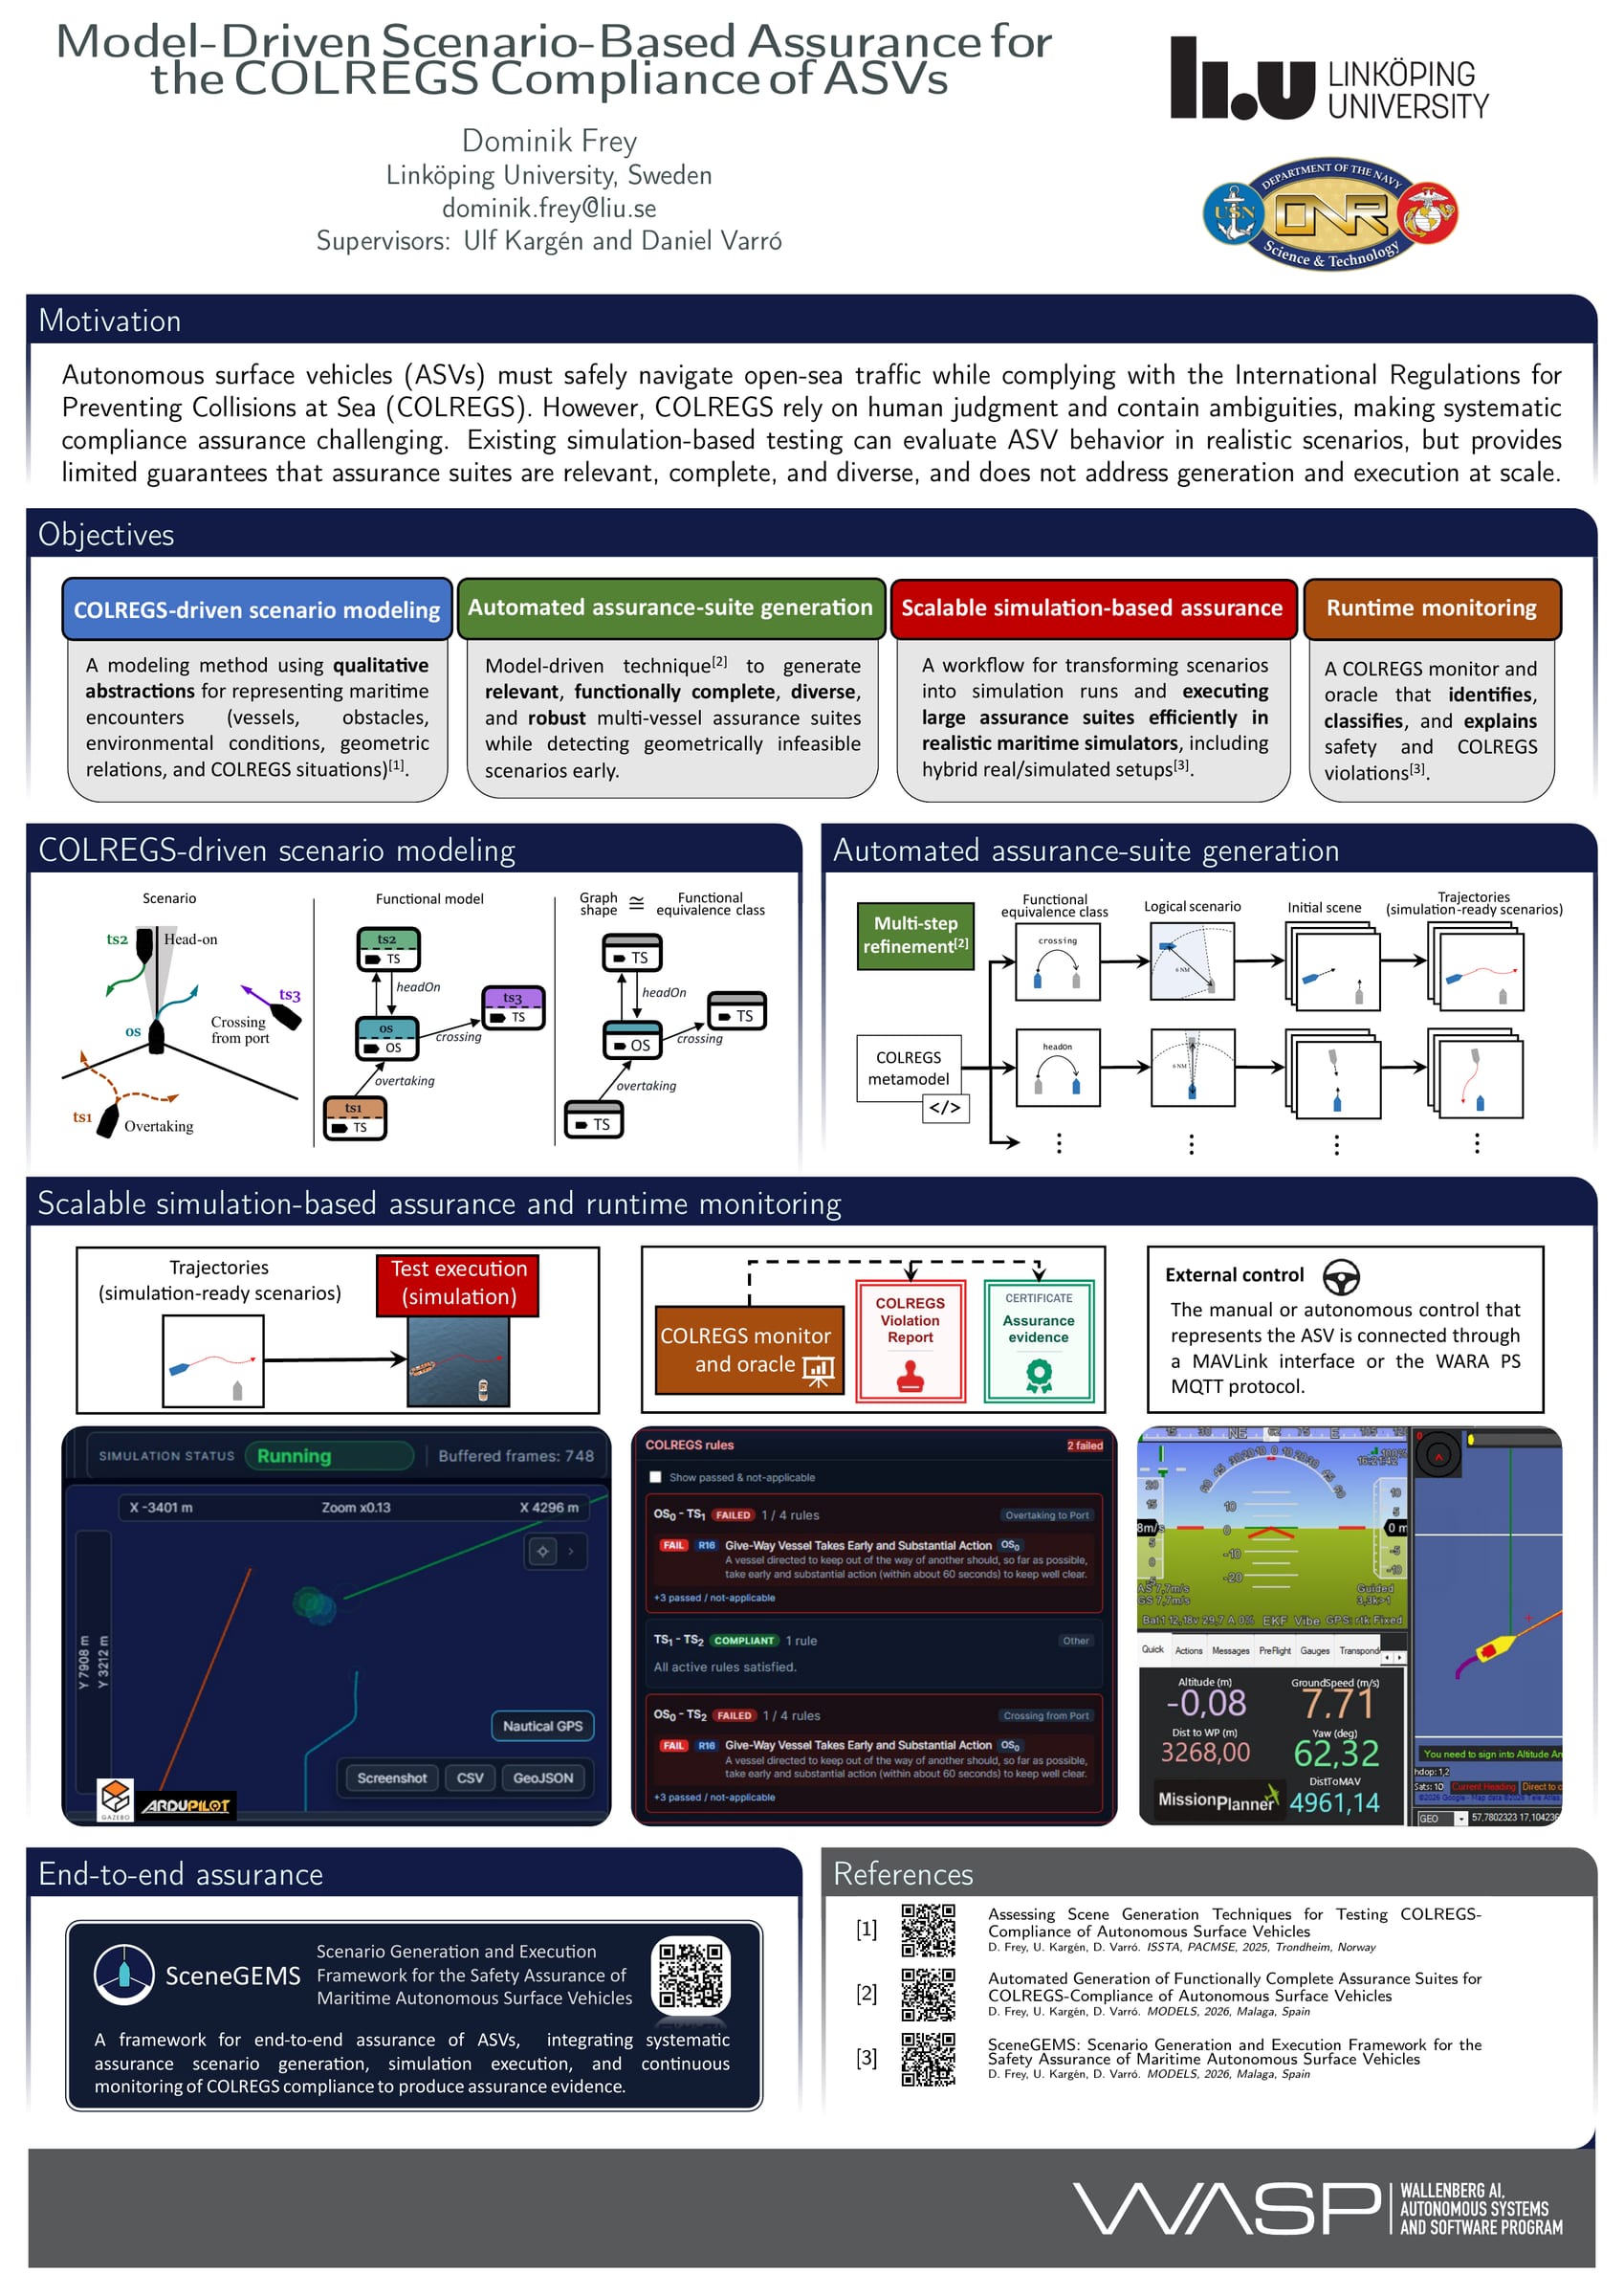
My presentation, Assuring the Safety of Maritime Autonomous Surface Vehicles with SceneGEMS: An End-to-End Framework from Scenario Generation to Simulation Execution, walked through:
- The assurance problem. COLREGS compliance, why multi-vessel scenarios are ambiguous, and why functional completeness matters.
- The pipeline. Functional equivalence classes → logical scenarios → initial scenes → trajectories, built on the Refinery graph solver and constraint solving.
- The integration. SceneGEMS publishes every simulated vessel on a WARA-PS MQTT topic. A vessel can follow its generated mission autonomously or be handed to an external ASV controller, and a runtime monitor evaluates COLREGS compliance.
- The roadmap. Orchestration through the WARA-PS core system, ASV runtime monitoring, trajectory validation, and execution at scale.
I also presented a poster, Model-Driven Scenario-Based Assurance for the COLREGS Compliance of ASVs, which covers the same work: scenario modelling, assurance-suite generation, simulation at scale and runtime monitoring.